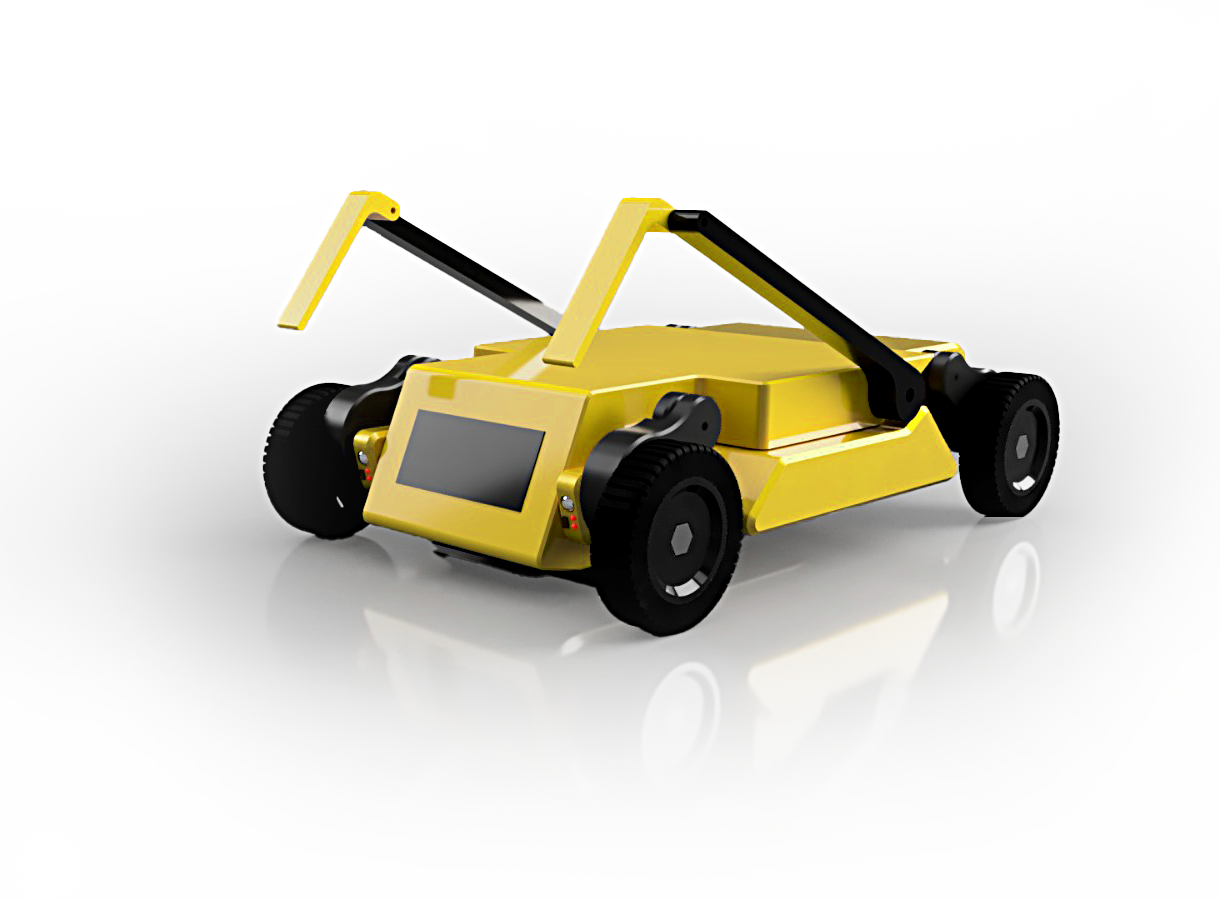
A little
cleaner

CLNR — Wireframe
Product page objectives
Consolidated working version | 15 October 2026
CLNR collects small litter from pedestrian spaces, helping municipalities keep public areas cleaner between regular cleaning operations.
Positioning
CLNR is a tool for sanitation operators. It complements existing teams and infrastructure; it does not replace them.
Visual reference
Technical capabilities are translated into large, clear numbers and concise benefit-led sections.
Editorial rules
One main idea per screen.Large typography and large numerical specifications.Short, confident, factual copy.Avoid generic feature-card grids.Avoid putting the product name in every headline.Never publish unverified technical figures as established specifications.Keep company information and other robot models on the company homepage or their own product pages.
01. Product introduction
Hero - Deschidere
Titlul central + Animatie
Hero title:
A little cleaner.
Subtitle:
Inspired by the smallest mess.
footer note:
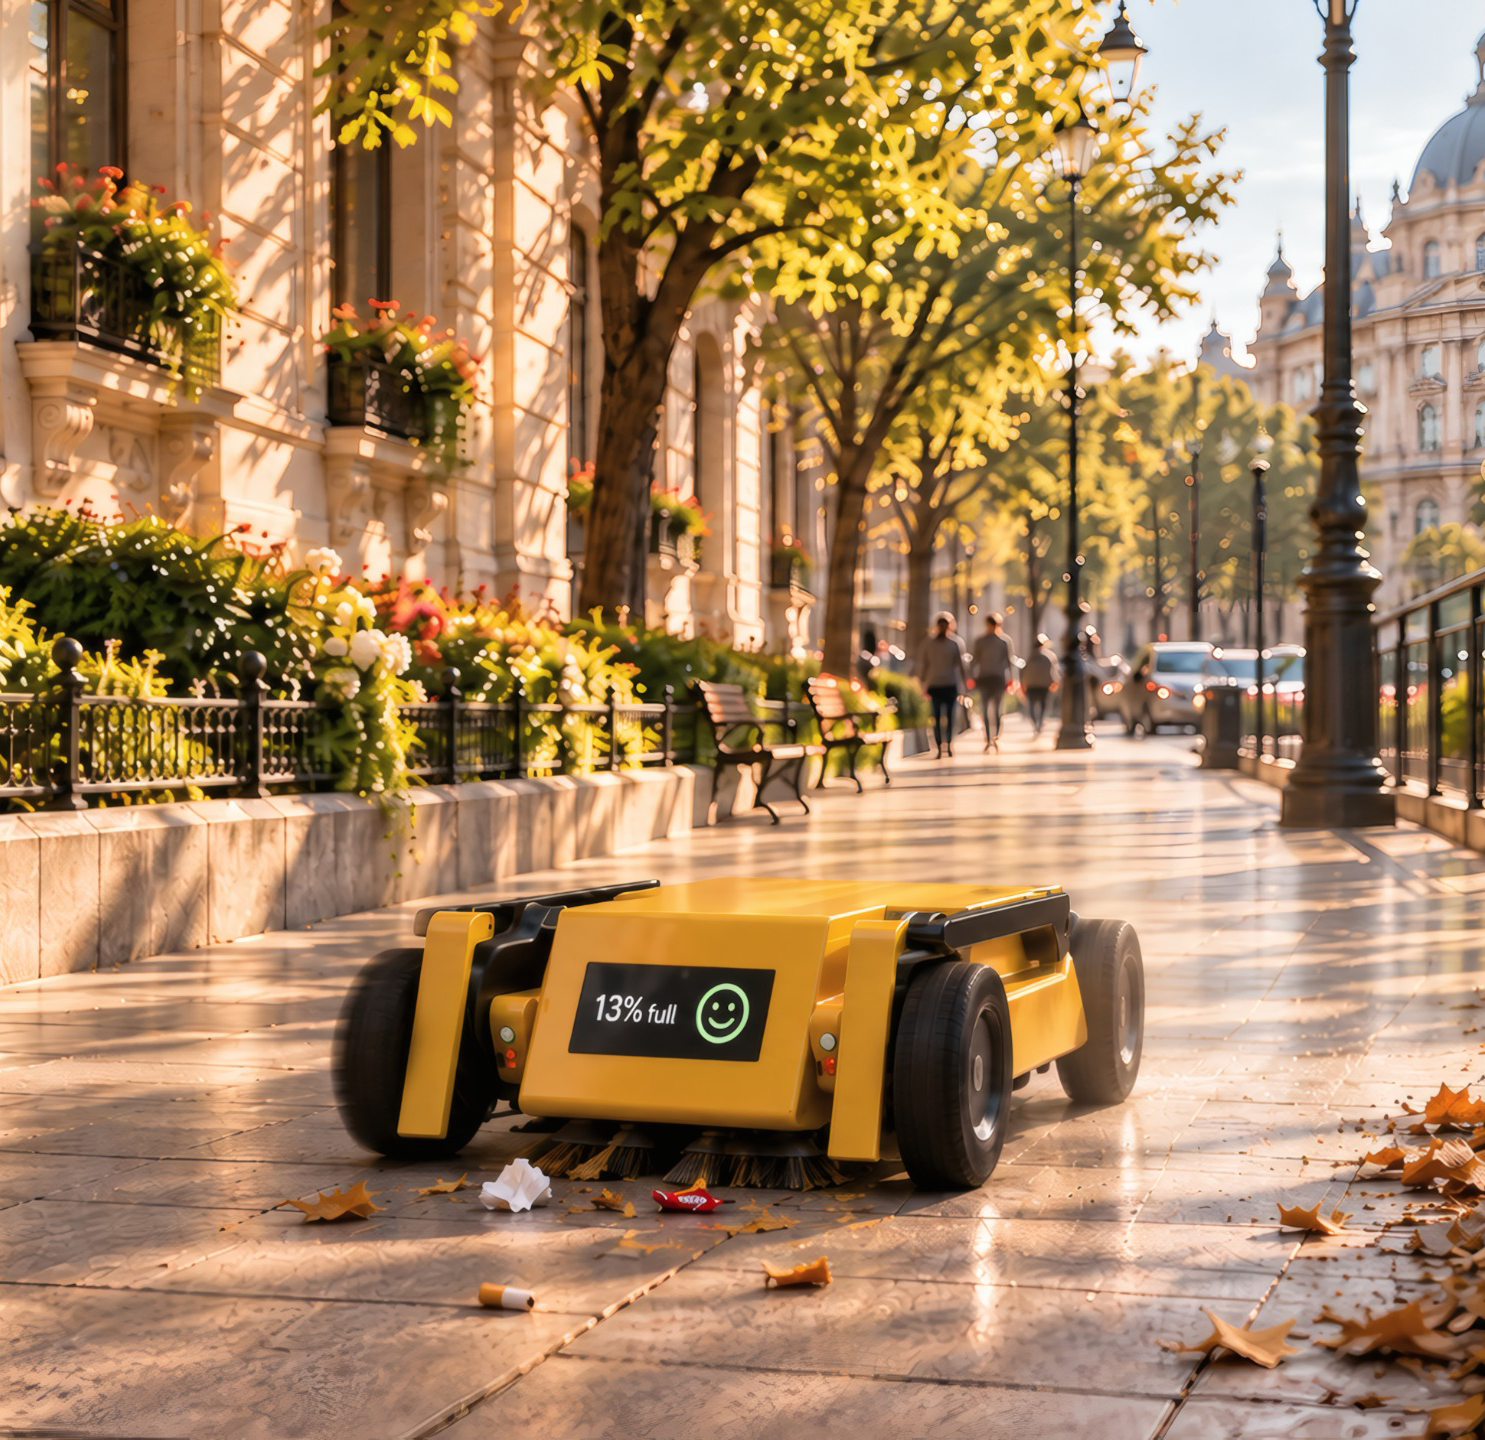
CLNR Sweeper is an industrial autonomous robot designed to support teams in maintaining everyday cleanliness across sidewalks, public walkways and urban parking areas.
Visual direction: A confident product introduction with minimal copy. Keep both brand lines together. Let the product itself carry the visual weight.
Animatie: unghi camera - nivel sol. Trece prin ecran un tip cu un catel, se vede doar de la genunchi in jos pana la adidasi. Dupa ce trece de 70% din ecran spre dreapta, cateva ambalaje marunte cad in ecran, pozitionate tot la nivelul picioarelor. La secunda 2.5 trece robotul si curata. Robotul este vazut din lateral, camera nu isi schimba pozitia. Robotul traverseaza ecranul o singura data si se intoarce in mijlocul ecranului total animatie: 3.5-4 sec.
Team
Eduard: dev Website + Copy
Eduard - Radu: product design
Eduard - Lucian: texturi, materiale, lumini, scenografie, motion si exporturi necesare
02. Adjustable height
Section 2
Titluri mari + Animatie
Title:
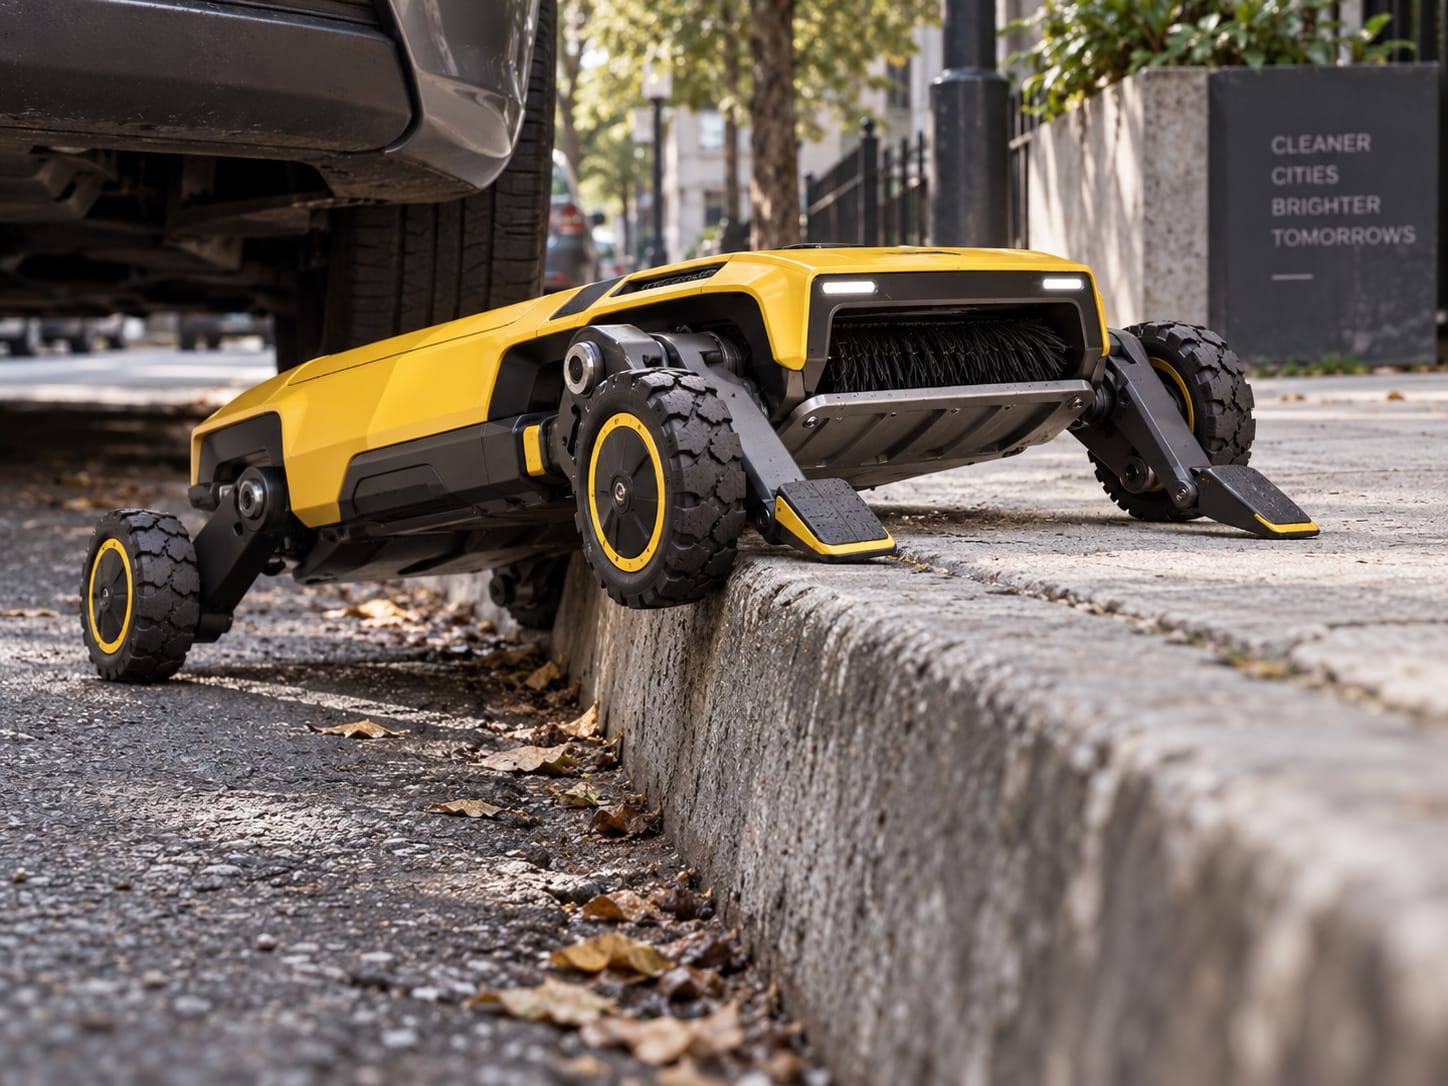
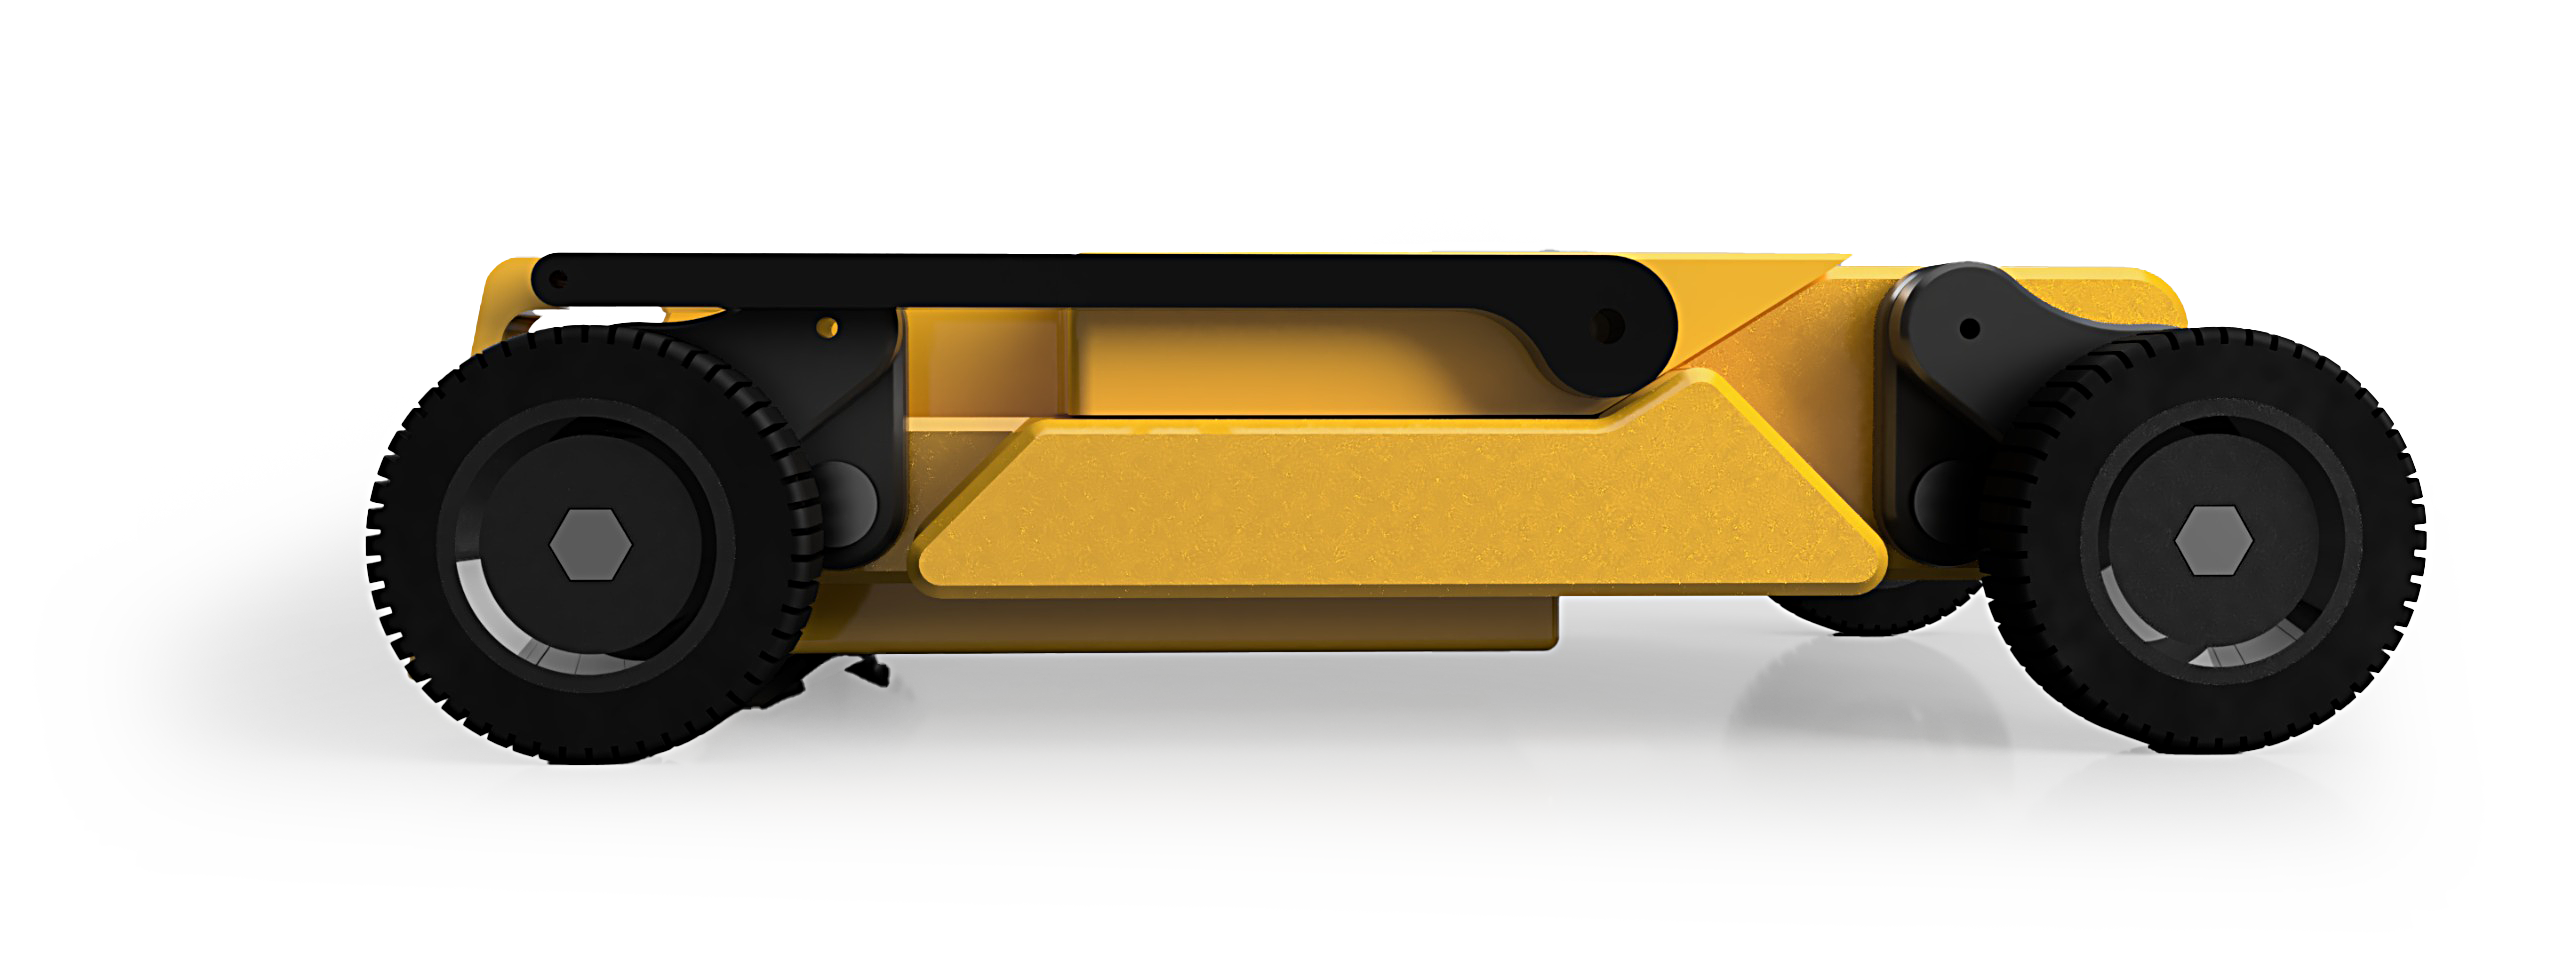
Only 120mm height
Subtitle
Access beneath compatible parked vehicles.
Title 2 (scroll interaction, same section/screen):
Return to the sidewalk.
Subtitle 2 (same time)
An adjustable body designed to reach low-clearance spaces and rise to climb curbs.
Visual direction Make 12–24 cm the dominant element.Show the robot in its lower and raised positions.Explain the practical difference between the two positions.Do not imply that it fits beneath every vehicle.Specification: Adjustable height approximately 12–24 cm.
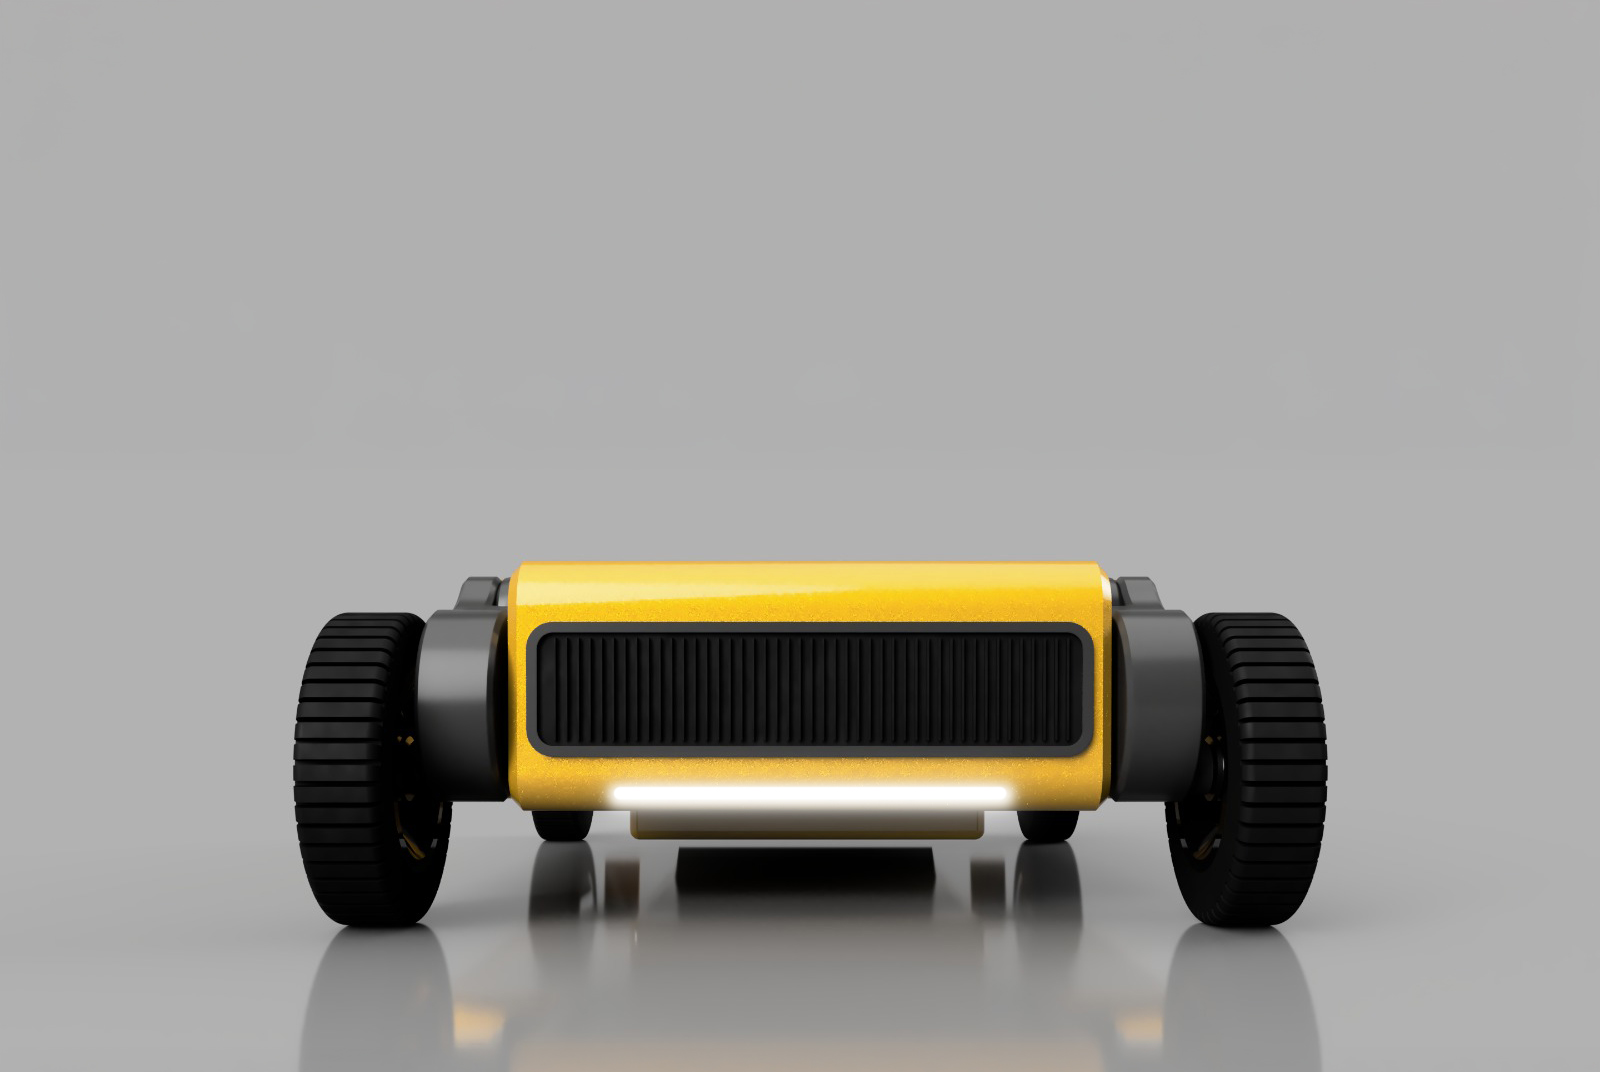
Animatie: scroll interaction. Robotul sta fixat in cadru indiferent de device, este vazut frontal la aceeasi dimensiune din section 01, coboara de la 140 la 120mm cu textul animat alaturat si dupa urca la 240 mm. Pe fundal, exista o schita (bluprint) reprezentand o roata de la masina si pragul de la usi. Robotul coboara la 120 animat, sub pragul masinii. Schita de masina este statica, ca intr-un manual de instalare. Doar robotul are miscare.
Team
Eduard: dev Website + Copy
Eduard - Lucian: scenografie, motion si exporturi necesare
03. Mapping and learning
Section 3
Titluri mari + Animatie
Titlu:
Mapping begins on day one -> sub el
8km/h (animat)
Subtitlu
Initial scanning speed, depending on conditions. Mapping begins on day one, alongside cleaning.
The robot observes its environment, learns local conditions and progressively improves how it schedules its missions.
Visual direction: Present the speed as a large, clearly labelled technical figure. Distinguish initial scanning speed from cleaning speed.
Animatie: vitezometru 0 to 8km/h, cu textul: "Mapping begins on day one." Dupa scanare, scade vitezometrul la 2-3km/h cu mesajul Cleaning. Robotul are aceeasi dimensiune si aceeasi pozitie in ecran. Nu se misca robotul in interfata, se misca backgroundul (mesh in miscare) la a doua animatie cand are 2km sau chiar 0km, se animeaza peria de sub el, poate animatie cu forasul care coboara inainte sa porneasca peria, foarte subtil. Important sa apara in dreapta sau stanga lui 2km/h sau 0km/h atunci cand strange. La animatia 1, mapare traseu la viteza de 8km, o sa avem acelasi stil de grafica, linii tehnice statice, reprezentand o mapare a unui trotuar cu cateva deseuri. Asemenea si la animatia nr 2., punem o schita (bluprint) a unui packaging de mici dimensiuni, nu incarcam interfata cu alte imagini colorate.
Focus pe produs deocamdata, spre final o sa avem si galerie de imagini.
Team
Eduard: dev Website + Copy
Eduard - Lucian: scenografie, motion si exporturi necesare
04. Predictive cleaning
Section 4
Titluri mari + App
Titlu:
Monday morning is different from Saturday night.
Subtitlu:
By learning pedestrian traffic patterns and how litter accumulates at different times and locations, the system can schedule cleaning missions around the changing needs of each area.
Visual direction: Show how the same location can require different cleaning schedules throughout the week. The benefit is smarter timing, not a promise of perfect prediction.
Animatie: Robotul nu apare in aceasta sectiune. Apare aplicatia cu diverse scenarii in care reprezentam grafic elemente pe displayul unui telefon mobil. Spre exemplu: icon pieton verde, icon cos de gunoi galben. In screen o sa avem mai multe zile afisate. in dreapta telefonului mobil, o sa apara un ceas, 08AM creste pana la 03AM. Pe screen in harta, apar mai multe iconuri suprapuse sau mai putine in functie de ora afisata in dreapta ecranului din site. In acelasi timp cand sunt mai putine icon-uri cu pietoni, pe harta din app-ul telefonului, apare robotul care pleaca pe traseul definit.
Team
Eduard: dev Website + Copy
Eduard - Lucian: scenografie, motion si exporturi necesare
Eduard- Paul - Calin: Functionalitati App vs Autonom
Eduard- Lucian: UX/UI App CLNR
05. Night operation
Section 5
Titluri mari + Animatie loop
Titlu:
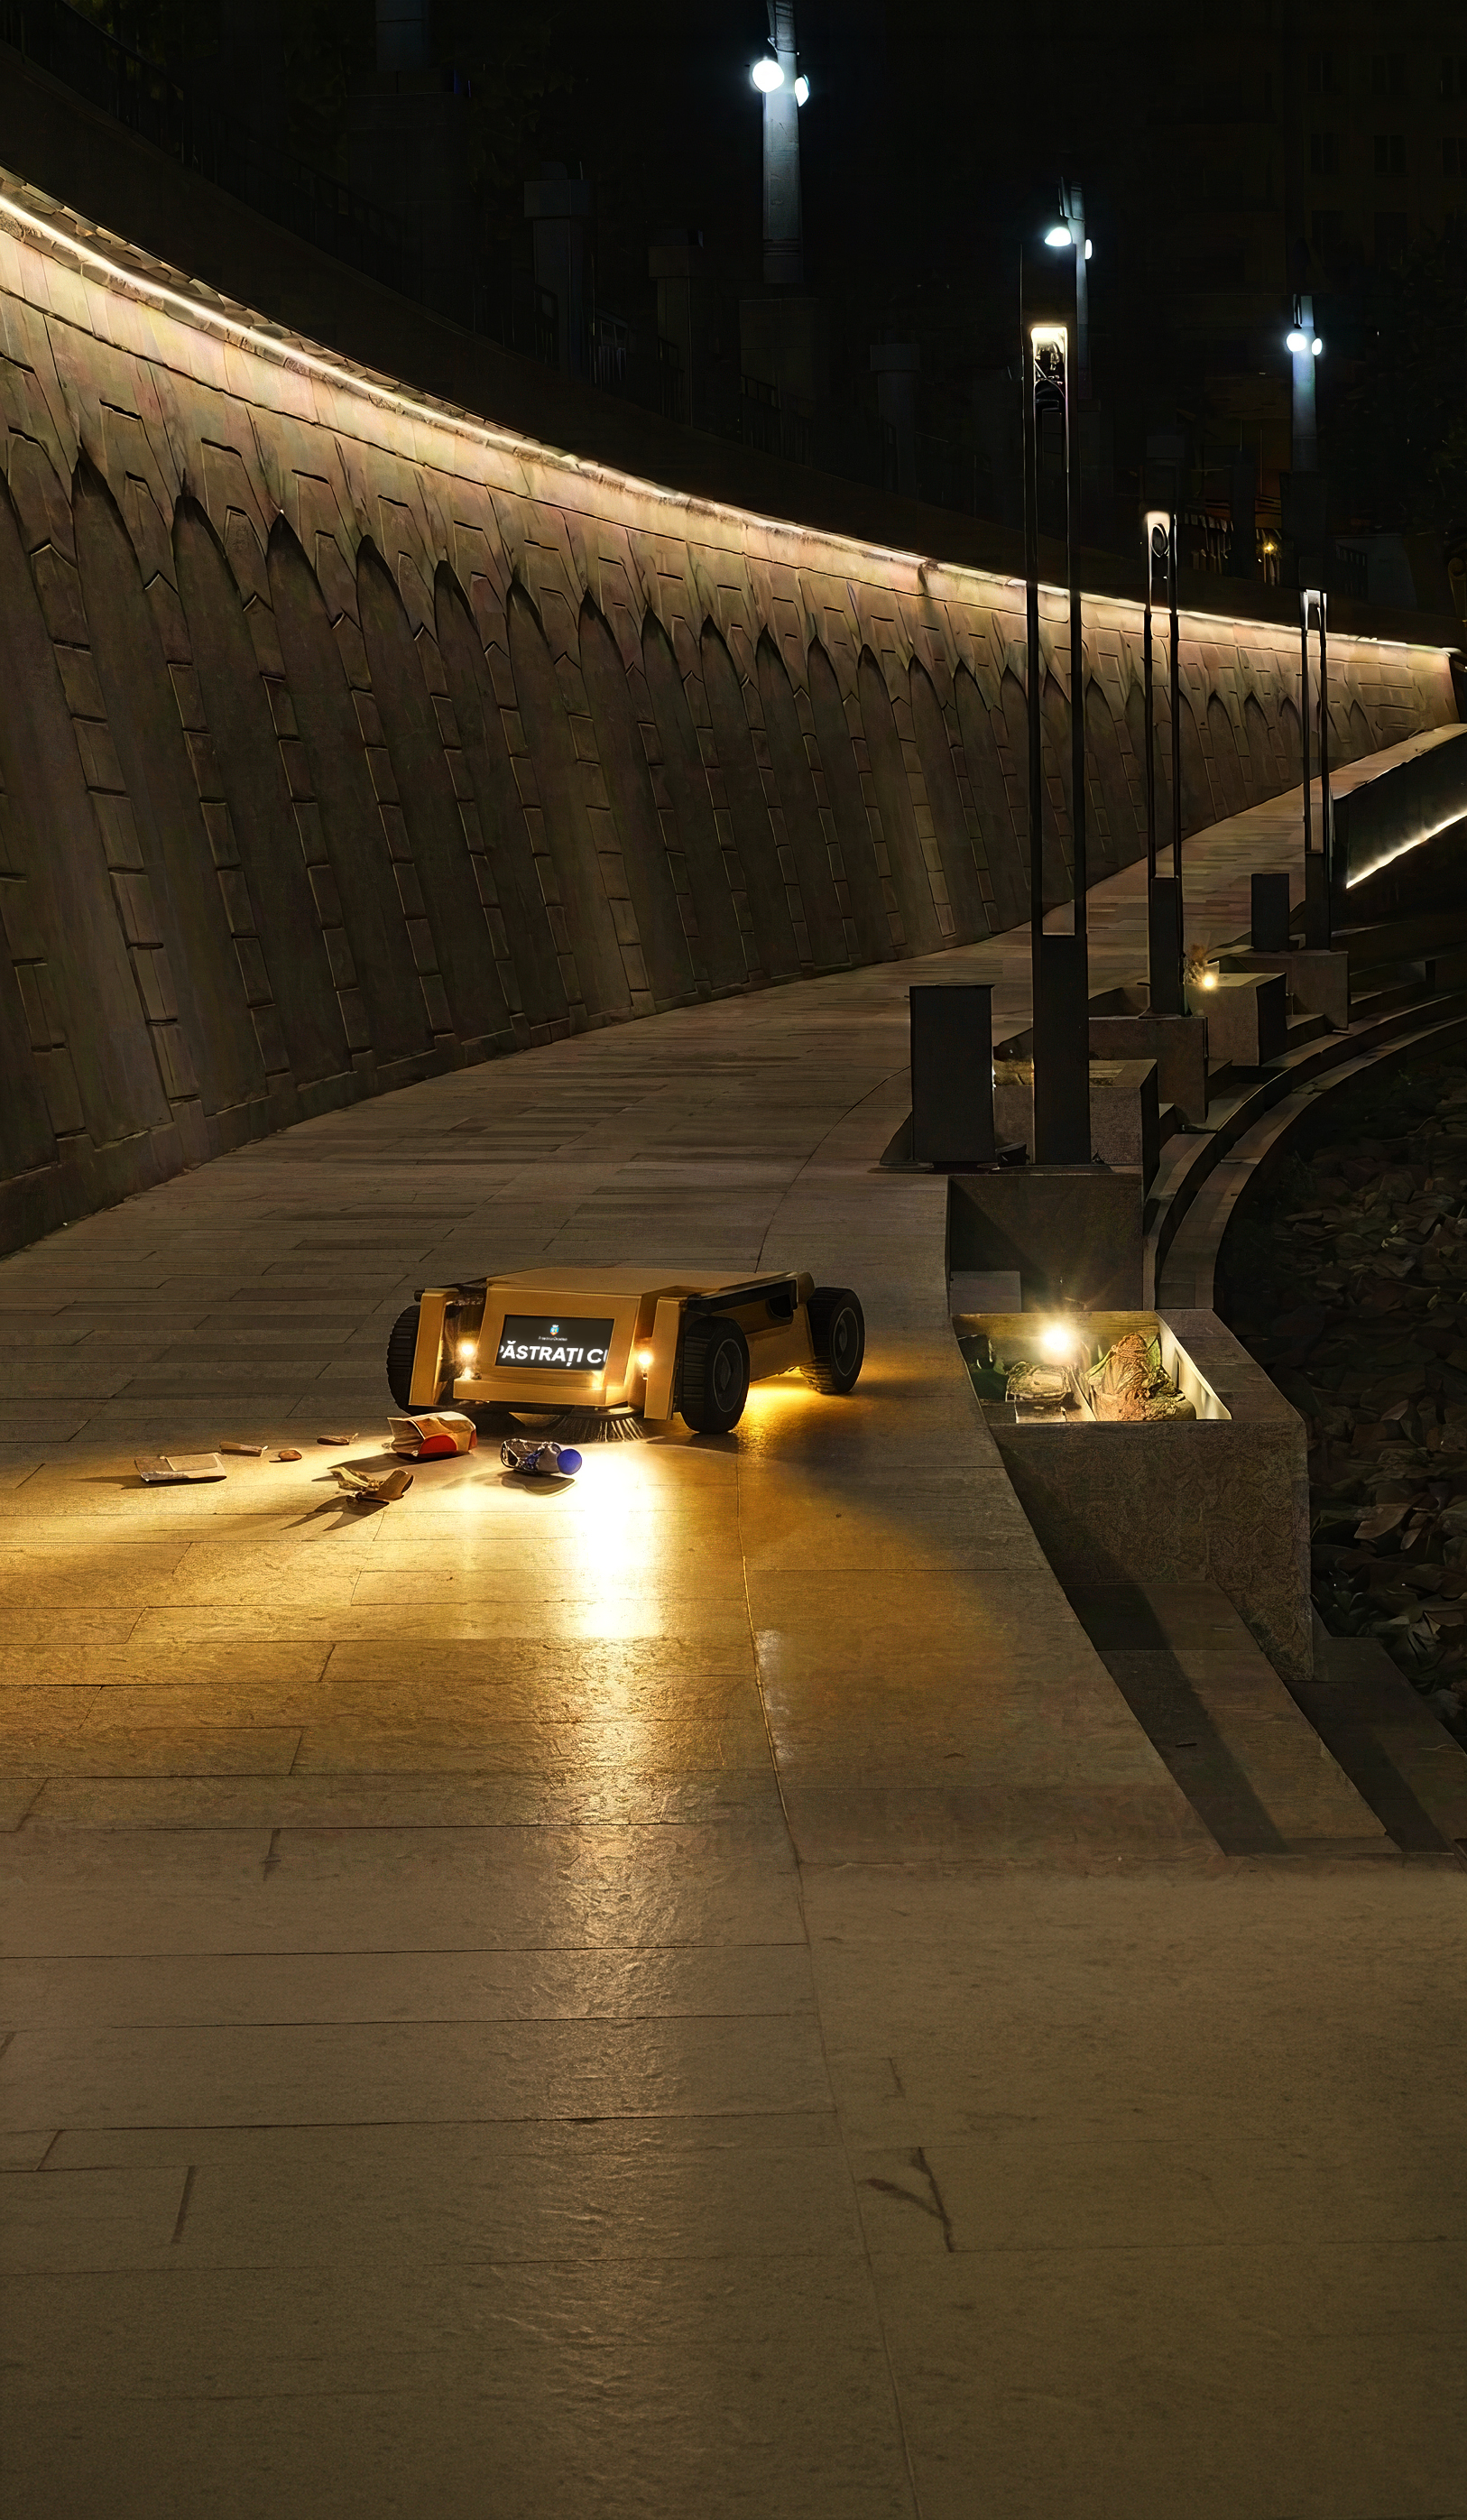
A quieter start to a cleaner day.
Subtitlu:
Designed for quiet operation during low-traffic hours, helping sanitation teams prepare public spaces before the morning rush. Scaneaza situatia actuala a deseurilor inainte ca echipa sa fie trimisa in teren.
Technical specification: Operating noise in dB should become a prominent numerical feature once measured. Do not invent a figure.
Vizual: Imagine asemanatoare cu cea de pe grup, pe timp de noapte, dar in format wide. Robotul lumineaza in fata cu leduri puternice proiectate doar pe asfalt iar in spate lumina galbena (salubritate). Putem anima lumina galbena din spatele robotului, pentru un efect fain in interfata.
Night operation: Rata/Gasca dormind (capul in puf) - Icon fixat oriunde se discuta despre Night operation
Team
Eduard: dev Website + Copy
Eduard- Lucian: procesare imagini + UX/UI
06. Continuous sanitation maintenance
Section 6
Titluri mari + Screen Phone
Title:
Clean between the rounds.
Subtitle
Everyday maintenance for existing sanitation services.
Body text
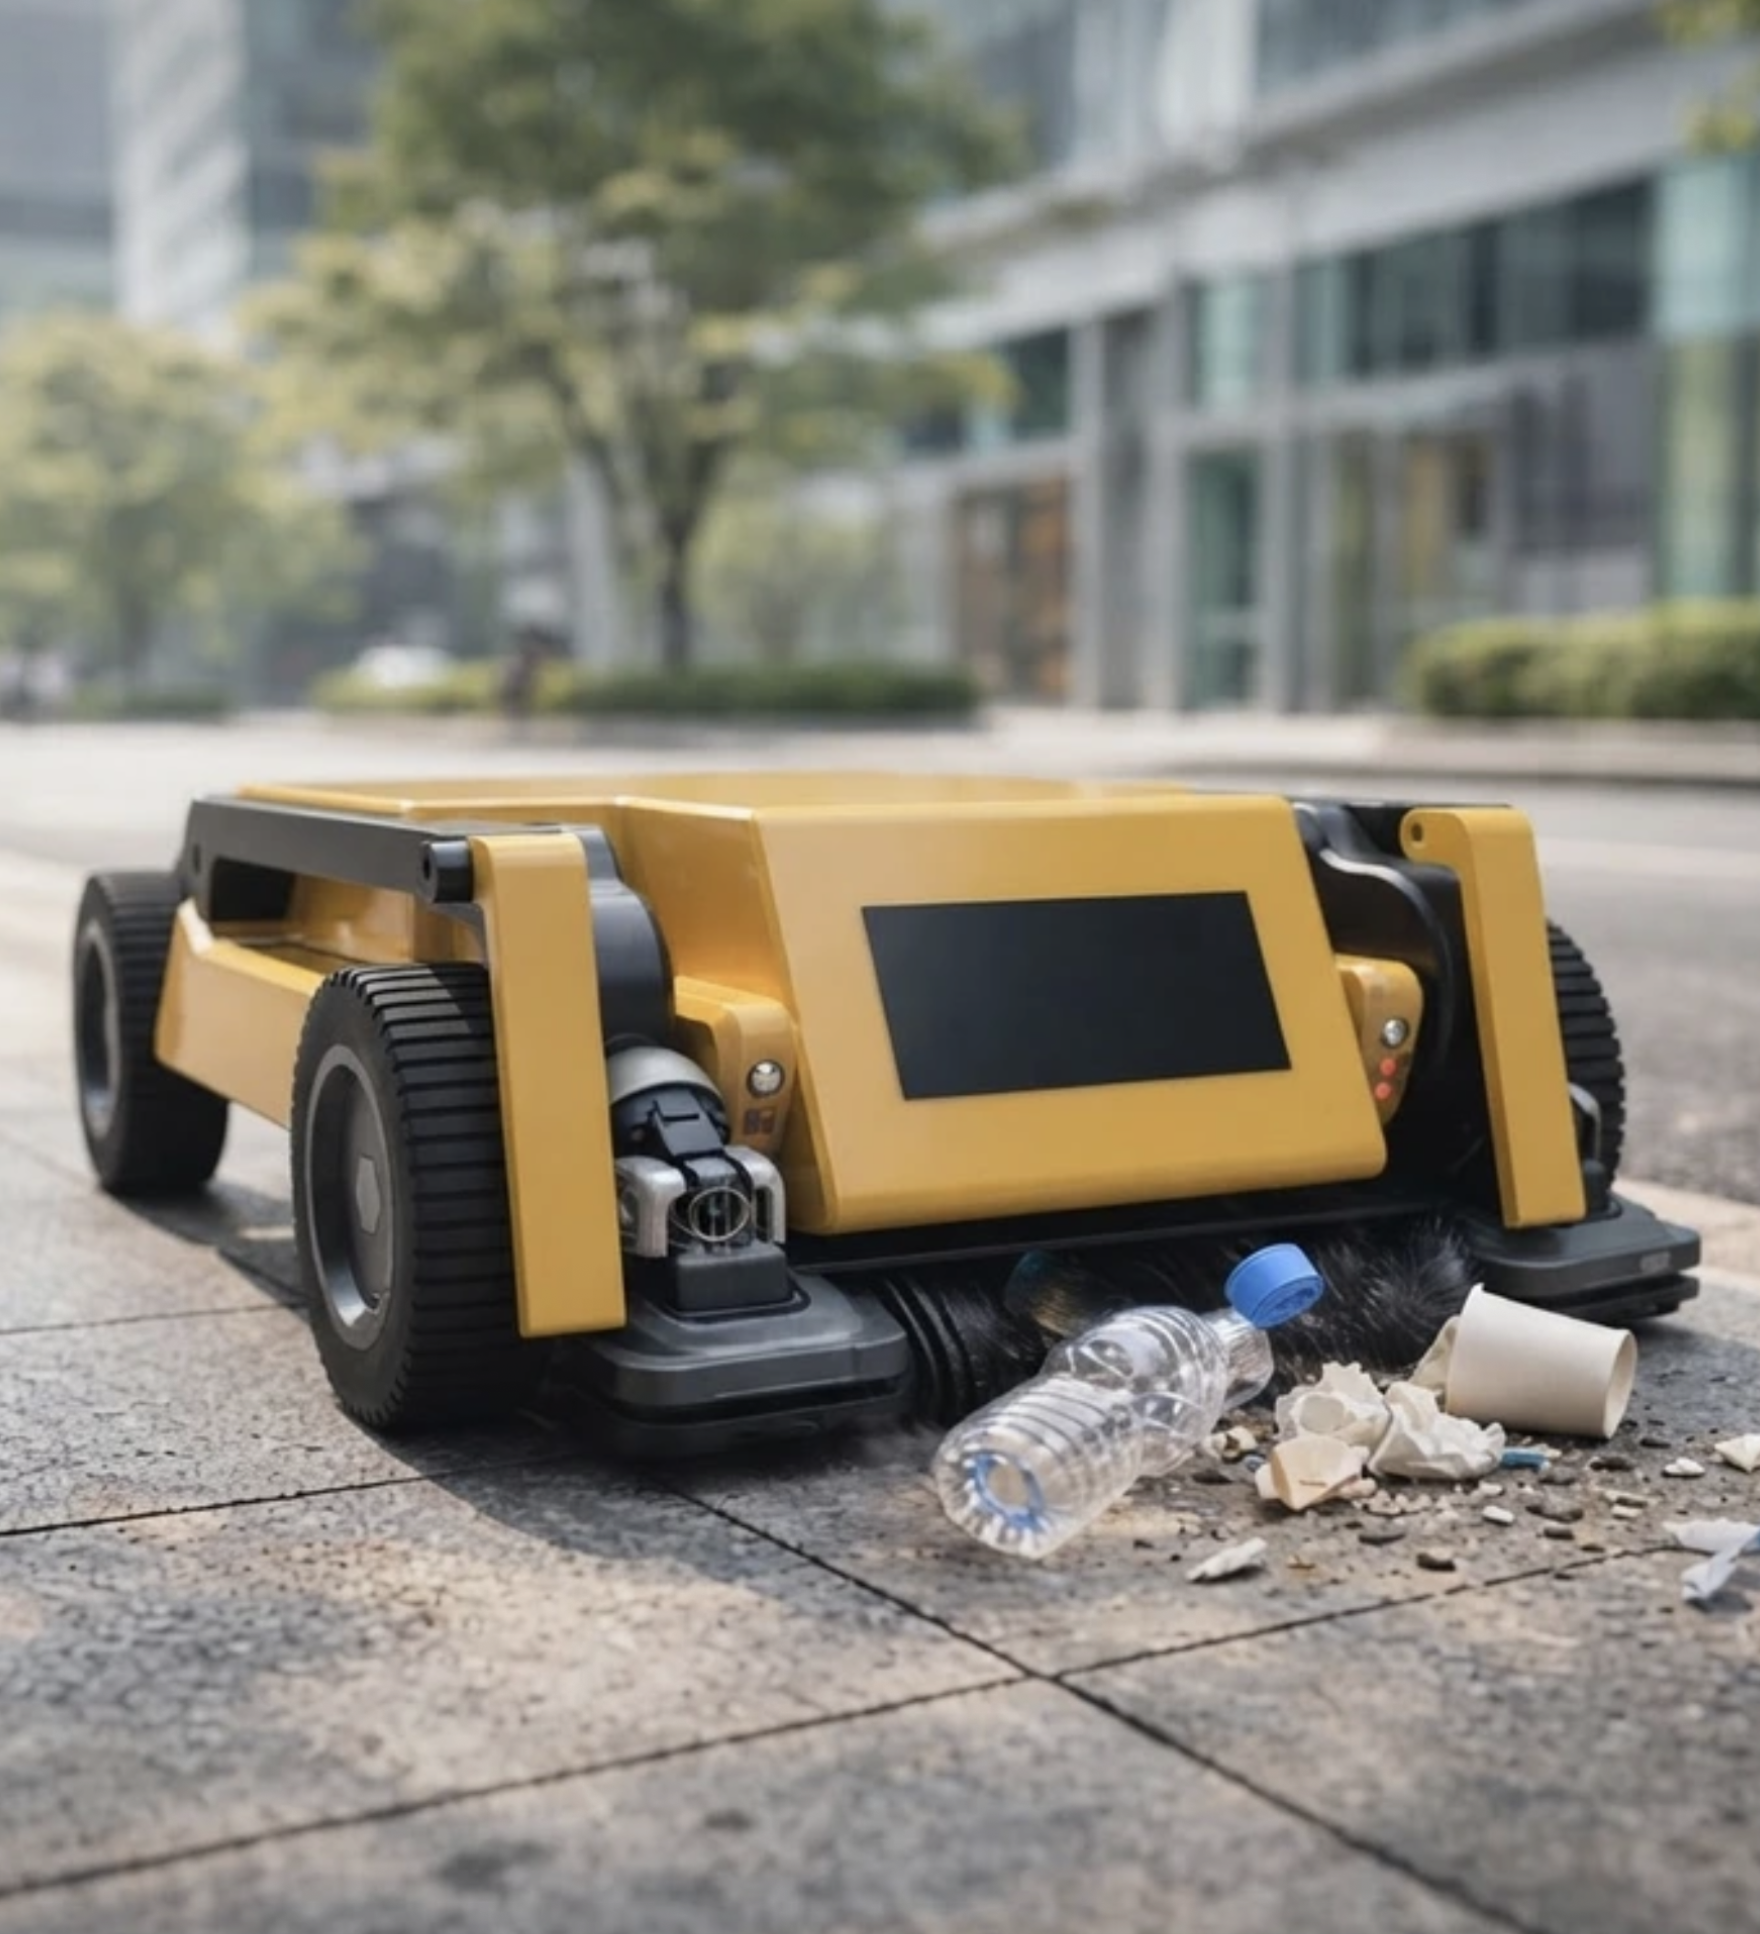
Cigarette butts, chewing gum, paper and small wrappers accumulate between regular cleaning interventions. Continuous, targeted collection helps sanitation teams maintain cleaner public spaces throughout the day.It complements the sanitation workforce. It does not replace it.
Visual direction: Explain the relationship between existing municipal cleaning rounds and the recurring litter that accumulates between them. This is a core product benefit, not a secondary feature.
Lista
Cleaning capabilities
Mechanical collection of small litter.
Sweeping and picker functions.
Designed for sidewalks and parking areas.
Can access spaces beneath compatible parked vehicles where physical clearance permits.
Does not vacuum.
Does not enter road traffic or cross streets.
Does not enter grass or uneven green spaces.
Team
Eduard: dev Website + Copy
Eduard- Lucian: procesare imagini + UX/UI
07. Existing waste infrastructure
Section 7
Titluri mari + Animatie importanta.
Title
The city bin becomes part of the robot.
Subtitle
Collected litter is designed to be transferred into compatible existing public waste bins, reducing the need for dedicated waste-disposal infrastructure.
Visual direction: Present this as an infrastructure advantage. The robot is designed to work within the city that already exists.Important distinction: The public bins used for waste disposal are separate from the robot's docking, charging and tool-hygiene station.
Technical validation: Confirm the waste-bin identification and emptying mechanism before describing it as a fully validated capability. The concept includes two telescopic arms that lift collected litter from inside the robot and transfer it into a compatible bin identified by the system.
Animatie: golire recipient + cos de gunoi - 3D - necesara o animatie de 3-4 secunde in care actioneaza bratele telescopice. Reprezentarea unui cos de gunoi urban (schita blueprint - layout).
Team
Eduard: dev Website + Copy
Eduard-Radu-Paul-Calin: mecanism golire + brate telescopice (Eu votez pentru a scoate sacul din el, nu cuva. Cuva face mizerie la cosul de gunoi cand este rasturnata. Sacul de gunoi (autosigilat la golire) protejeaza si cuva de mizerie. La igienizare robotul se curata mai usor, doar de praf)
Calin-Paul: programare creier CNLR - trebuie sa ne iasa asta.
Cautam cosurile de gunoi din Romania in prima etapa sa vedem care sunt posibilitatile in care poate nimeri cosul cand vrea sa se goleasca.
Toti au ramas surprinsi la functia de golire in cos de gunoi stradal. Nu putem renunta la acest avantaj.
Eduard - Lucian: scenografie, motion si exporturi necesare
08. Autonomous operation
Section 8
Titluri mari + Autoplay Slider
Titlu:
Swap Battery and back to work.
Automatically.
Subtitlu
The robot follows its configured mission, it swap battery when needed and resumes cleaning. Learning continues throughout operation.Operators define the working area, schedule and permitted level of autonomy, while monitoring mission status and exceptions.
Visual direction:
Show a simple cycle: mission, cleaning, charging, return to work. Keep operator involvement clear and reassuring.
ASlider + thumb
S1 Cleaning and learning take place in overlapping cycles + illustration
S2 The robot swap battery and resumes work. + illustration
S3 Operators configure zones and permitted operating times. + illustration
S4 Notifications identify situations that require attention. + illustration
Team
Eduard: dev Website + Copy
Eduard-Lucian: Illustratii grafice
Eduard-Lucian: App UX/UI
09. Integrated air-quality sensors
Section 9
Titluri mari + Phone
Title:
Mobile air-quality sensors. Built in.
Subtitle
Every unit includes air-quality sensors as a standard feature.
Body text
As the robot moves through an area, it collects location-specific measurements that complement stationary monitoring and can help identify places requiring further assessment.
Animatie: notificari screen app. Exemplu: a detectat o anomalie a aerului - arderi ilegale. Exemplu2: A detectat deseuri voluminoase depozitate ilegal.
Team
Eduard: dev Website + Copy
Eduard-Lucian: Illustratii grafice
Eduard-Lucian: App UX/UI
9.1. Environmental alerts
Section 9
Titluri mari + Phone
Title
When cleaning isn't enough.
Subtitle
Some situations require a different response.
Body text:
Bulky waste
Discarded furniture, appliances or other items that the robot cannot collect can be reported so that a responsible team can arrange removal.
Unusual air-quality readings
Measurements outside expected ranges can trigger a notification for further assessment.
Environmental incidents
Relevant observations can help responsible teams investigate and respond through established procedures.
Important limitations
The robot reports observations; it does not independently establish the cause of an incident.
An alert does not itself establish a legal offence or determine a sanction.
Response workflows depend on sensor validation, system configuration and the responsible authority's procedures.
Team
Eduard: dev Website + Copy
Eduard-Paul-Calin: Stabilirea tuturor functionalitatilor senzorului de aer.
Eduard-Lucian: Illustratii grafice
Eduard-Lucian: App UX/UI
11. Operator control
Section 10
Titluri mari + Phone
Title:
Set the mission. Follow the results.
Subtitle:
Operators configure the area, schedule and operating rules, then monitor mission completion and receive notifications when intervention is needed.
Animatie sectiune:
Aplicatia desfasurata pas cu pas pentru un nou user cu urmatoarele UI-uri: setari robot, configurare operator, stabilirea patrularii, restrictii, live track, change mision, programare, rapoarte si istoric, notificari si alerte, setari performanțe robot, monitorizare statii de incarcare.
Securitate si protectie (draf):
1. Isi opreste functiile daca detecteaza picior in apropierea lui sau daca detecteaza transport alternativ pe trotuar, la mai putin de 1.5 metri de el. Previne sa nu mature picioare, biciclete si babe curioase.
La stand-by, peria sau restul de unelte, brate telescopice, se ascund in caroserie.
Daca este intors cu rotile in sus, nimeni nu are acces la perie, foras, mecanisme, etc. toate se inchid in interior. Cred ca forasul este trapa de siguranta la izolarea carcasei.
2. daca detectecteaza o presiune superiorara mai mare de 2kg, intra in protectie, isi opreste functiile, se intinde pe asfalt. La fel, se ascund uneltele si mecanismele de curatare pentru a le proteja in caz de este calcat de o masina sau daca il calaresc copiii.
3. daca este bagat la portbagaj si dus la padure, alerteaza operatorul.
Imediat ce paraseste spatiul de patrulare marcat de operator, strada, jobul dat, incepe sa tipe.
Bateriile de swap, la fel, alarma la fel de puternica ca la trotinete.
4. Bateriile sunt si ele monitorizate prin app de catre operator. Operatorul observa statiile de incarcare in app la fel ca pe robot si are acces la istoric incarcare, consum, locatie curenta baterie (in caz de furt)
5. Robotul este waterproof la o adancime de maxim 15 metri timp de 1-2h. Carcasa se izoleaza ermetic cand robotul intra in stand-by in caz de ridicare de la sol sau daca paraseste traseul de patrulare.
6. Statiile de swap battery pot fi mobilier urban -> banca pentru pietoni sub care se retrage robotul sa-si schimbe bateria. Prevenim furturi, bateriile expuse la temperaturi extreme, putem controla cat de cat temperatura la interior. Ajuta la retragerea robotului intr-un spatiu inchis atunci cand nu patruleaza deloc => casuta lui cu usa si cheie fara sa fie agasat pe strazi.
1 banca = 2 roboti = 4 baterii
7. GDPR free: senzorii si camerele sunt directionate la nivelul solului. Robotul mapeaza "picioare", nu fete de oameni. Nu stiu exact cum o sa identifice cosurile de gunoi, acestea sunt de regula de 600-700mm inaltime, in diverse forme. M-am gandit ca poate ar fi bine sa montam un barcode in partea de jos, pe fiecare cos compatibil si sa il scaneze robotul. Doar ca nu mai este autonom si incurcam administratiile.
8. Battery Lifetime: optiuni de reglare afisaj display, lumini, viteza de patrulare.
9. Backup battery - non swap: sustine location + transmitere notificari in caz de battery failure, furt si deconectare, alte erori de energie catre creierul robotului.
10. Robotul isi programeaza/reprogrameaza rutele de patrulare in functie de conditiile meteorologice curente.
11. Senzorii de identificare deseuri ilegale sau de aer contaminat, pot transmite notificari de tip alerta, direct catre garda de mediu daca operatorul confirma.
Team
Eduard: dev Website + Copy
Eduard-Lucian: Illustratii grafice
Eduard-Lucian: App UX/UI
12. Closing
Section 12
Table
TECH specs.
@Paul adaugati randuri la tabel, dar am nevoie de el completat. ma ajuta informatiile la sectiunile de mai sus.
Operating boundaries
The robot operates autonumus in configured pedestrian and parking areas.
It stays on sidewalks and designated areas, never entering road traffic or crossing streets.
Access beneath parked vehicles depends on actual clearance.
It does not replace regular sanitation crews.
Bulky waste requires human collection.
Air-quality alerts indicate conditions and data for assessment, not confirmed diagnoses of fire, accidents or other incidents.
Team
Eduard: dev Website
Eduard-Paul-Calin-Radu